Deep-dive articles on actuator selection, performance analysis, and real-world applications. Written by ZHR Motor's engineering team to help you make informed decisions.
Choose a topic, compare the relevant model specifications, then request the evidence needed for your design. Article guidance does not establish the performance or interface support of every actuator configuration.
Start with the load case, joint location, available space and integration constraints.
Separate rated and peak torque; check speed, mounting, cooling and the complete motion cycle.
Confirm the exact interface, firmware and controller. A CAN port alone does not establish CANopen support.
Compare the full installed assembly, feedback arrangement and load-dependent positioning behavior.
Use the product pages to compare models and the document center to check file availability. For an engineering inquiry, include rated and peak load, speed, duty cycle, envelope, voltage, interface, quantity and required delivery date.
How low reflected inertia, dual encoders, QDD design and EtherCAT/CANopen/CAN FD control shape humanoid hip, knee and ankle actuator selection.

Choose compact electric cylinders by stroke, rated force, repeatability, duty cycle, wiring and feedback instead of peak force alone.

Select finger, thumb and compact gripper actuators by envelope, travel, fingertip force, sensing, wiring and heat.

Compare servo electric cylinders and pneumatic cylinders for repeatable short-stroke adjustment, coating equipment and compact machine axes.
Selection guide for QDD-style humanoid joints, low reflected inertia, dual encoders, torque transparency and ZHR-P/ZHR-H mapping.
Selection guide for all-in-one robot joint actuators. Compare DIY BLDC stacks, smart servos, CyberGear and ZHR integrated servo joint modules.
Compare smart servos, CyberGear, DIY BLDC stacks and ZHR servo joint modules by torque, protocol, encoder, voltage and size.
Learn when CyberGear is enough and when to move to higher-torque ZHR-P servo joint modules with industrial bus options.
Learn when quasi-direct-drive actuators fit humanoid hips, knees, and ankles. Covers gear ratio, reflected inertia, backdrivability, shock load, torque control, and ZHR-P selection.
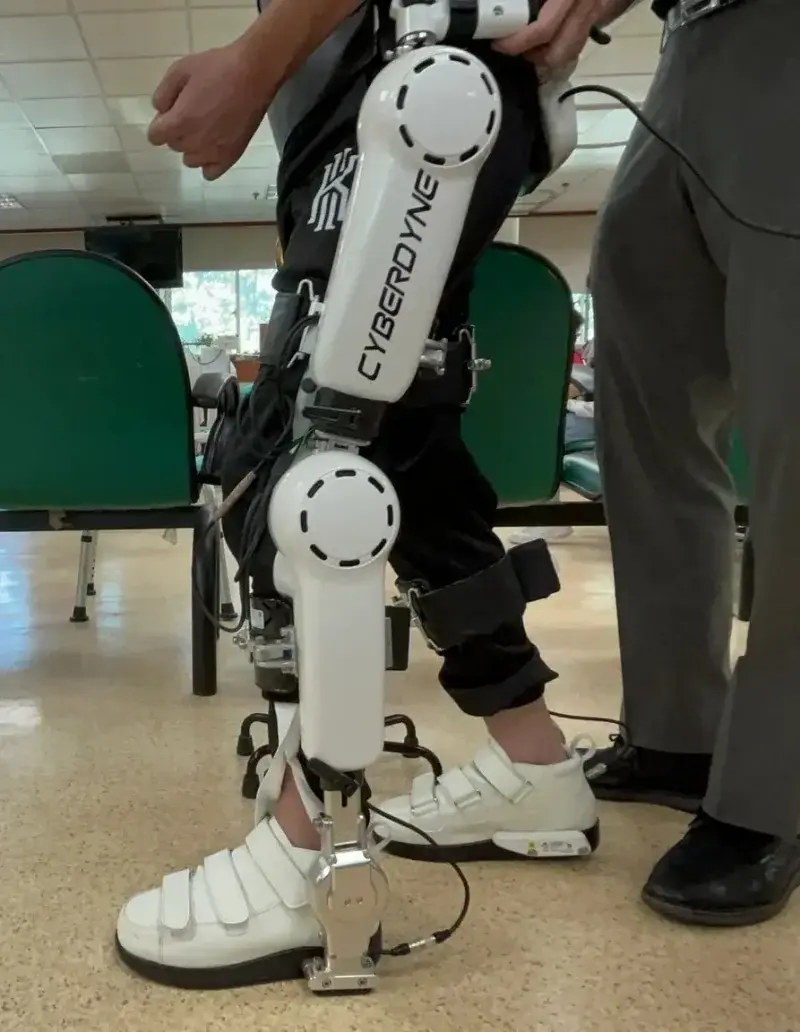
Engineering guide to backdrivable actuators for exoskeletons, humanoid legs, and cobots. Covers mechanical transparency, reflected inertia, gear ratio, and ZHR-P selection.
Compare servo motors vs stepper motors for robot joints: torque-speed characteristics, closed-loop vs open-loop control, BLDC advantages, application guide, and cost analysis for humanoid, cobot, and industrial robots.
Explore strain wave actuator design, reduction ratios and positioning behavior. Compare ZHR-H specifications with your torque, mass and integration requirements before selection.
ISO 9001 certified manufacturer since 2015. 2-4 week lead time, flexible MOQ, in-house CNC & cleanroom, 6-stage testing, custom engineering, global shipping to 15+ countries.
Find the right harmonic joint motor supplier for your robot. Compare ZHR Motor's capabilities with industry benchmarks for OEM customization, lead times, MOQ, and quality assurance.
A complete 5-step framework for selecting humanoid robot actuators. Includes torque calculation methods, harmonic vs planetary decision matrix, and joint-by-joint recommendations.
An honest, data-driven comparison of ZHR Motor, Harmonic Drive LLC, and Maxon across torque density, backlash, price bands, and total cost of ownership for robot integrators.
Design the right communication architecture for your robot arm. Compare single-protocol vs hybrid CANopen+EtherCAT designs with real-world cost and performance trade-offs.
Extend actuator lifespan with proper maintenance. Preventive schedules, harmonic vs planetary specific care, diagnostic methods, and troubleshooting for common joint failures.
Discover the actuator choices behind humanoid robots like Tesla Optimus. Compare harmonic vs planetary gearboxes, torque formulas, and ZHR alternatives.
A selection guide for harmonic reducer joint motors in collaborative robots. Review load requirements, positioning accuracy, assembly mass and model-specific evidence before design-in.
A comprehensive buyer's guide for selecting planetary robot actuators and integrated joint modules customized for industrial robotics, humanoids, and exoskeletons.
A definitive breakdown of strain wave kinematics. Understand how the Wave Generator, Flexspline, and Circular Spline eradicate backlash in precision robotics.
Discover the anatomy of integrated humanoid actuators. Learn how engineers fuse frameless motors, zero-backlash reducers, and EtherCAT drivers.
Compare rated and peak torque density using the same assembly mass and operating conditions. Review architecture trade-offs, thermal duty and the evidence needed for a model-specific comparison.
Learn why a zero backlash robot joint is critical for precision automation, cobots, and surgical applications, and discover how harmonic reducers eliminate mechanical play.
Compare harmonic and planetary joint modules by backlash, torque, mass, efficiency and integration requirements. Use the selection checklist to identify the model-specific data your robot arm needs.
Compare harmonic and planetary architectures through positioning behavior, efficiency, external loads, service life and backdrivability. Verify numerical ratings against exact models and test conditions.
Engineering comparison of DIY frameless motor assemblies vs all-in-one joint modules. Discover the hidden costs $200-500+ engineering hours -and when each approach makes economic sense.
Learn the core causes of joint play, arcmin vs arcsec measurement tactics, and how zero-backlash harmonic reducers eliminate precision loss in robots.
Discover why zero-backlash harmonic reducers are essential for collaborative robots. A complete guide to understanding robot joint motors and actuators.
Master humanoid robot actuator torque density (Nm/kg). Learn how to calculate, optimize, and select the right joint motors for maximum performance. Expert guide on frameless motors, harmonic reducers, and integration design.
Explore how backlash affects positioning and force-control behavior in collaborative robot joints. Actuator precision alone does not establish the safety of a complete robot application.
Master the selection of actuators for humanoid robots, cobots, and exoskeletons. Data-driven comparison of frameless vs housed motors.
Review torque-density selection for humanoid robots and cobots. Distinguish rated from peak torque, define assembly mass and check thermal duty and positioning requirements.
Understanding Nm/kg ratio, industry benchmarks, calculation methods, and optimization strategies. The definitive reference for actuator performance metrics with product comparisons and testing guidelines.
In-depth case studies of ZHR actuators in collaborative robots and lower-limb exoskeletons. Real performance data, technical challenges, solutions, and ROI analysis from actual deployments.
Step-by-step guide: torque requirements by joint, reducer type, motor constant Km, control bandwidth, form factor—with a joint-by-joint selection table and ZHR product recommendations.
Learn the terminology and working principle of strain wave gearing, then compare its mechanical layout and positioning characteristics with planetary alternatives using model-specific data.
Mechanical transparency, quasi-direct drive topology, hip/knee/ankle torque specs for 75 kg users, and bandwidth requirements. With ZHR-P series selection table for industrial exoskeletons.
Compare EtherCAT, CANopen and CAN FD by actual device support, traffic budget and measured system timing. Confirm the selected ZHR model and firmware before planning integration.
Review backlash units, measurement conditions and how joint errors accumulate. Specify the load, direction reversal and acceptance method before comparing reducer performance.
Our engineering team provides free technical consultations to help you choose the right actuator for your application.
Schedule Consultation