Back

ZHR-P Series Spec Sheets

6 Pages (Strict PDF Data)
Request Quote
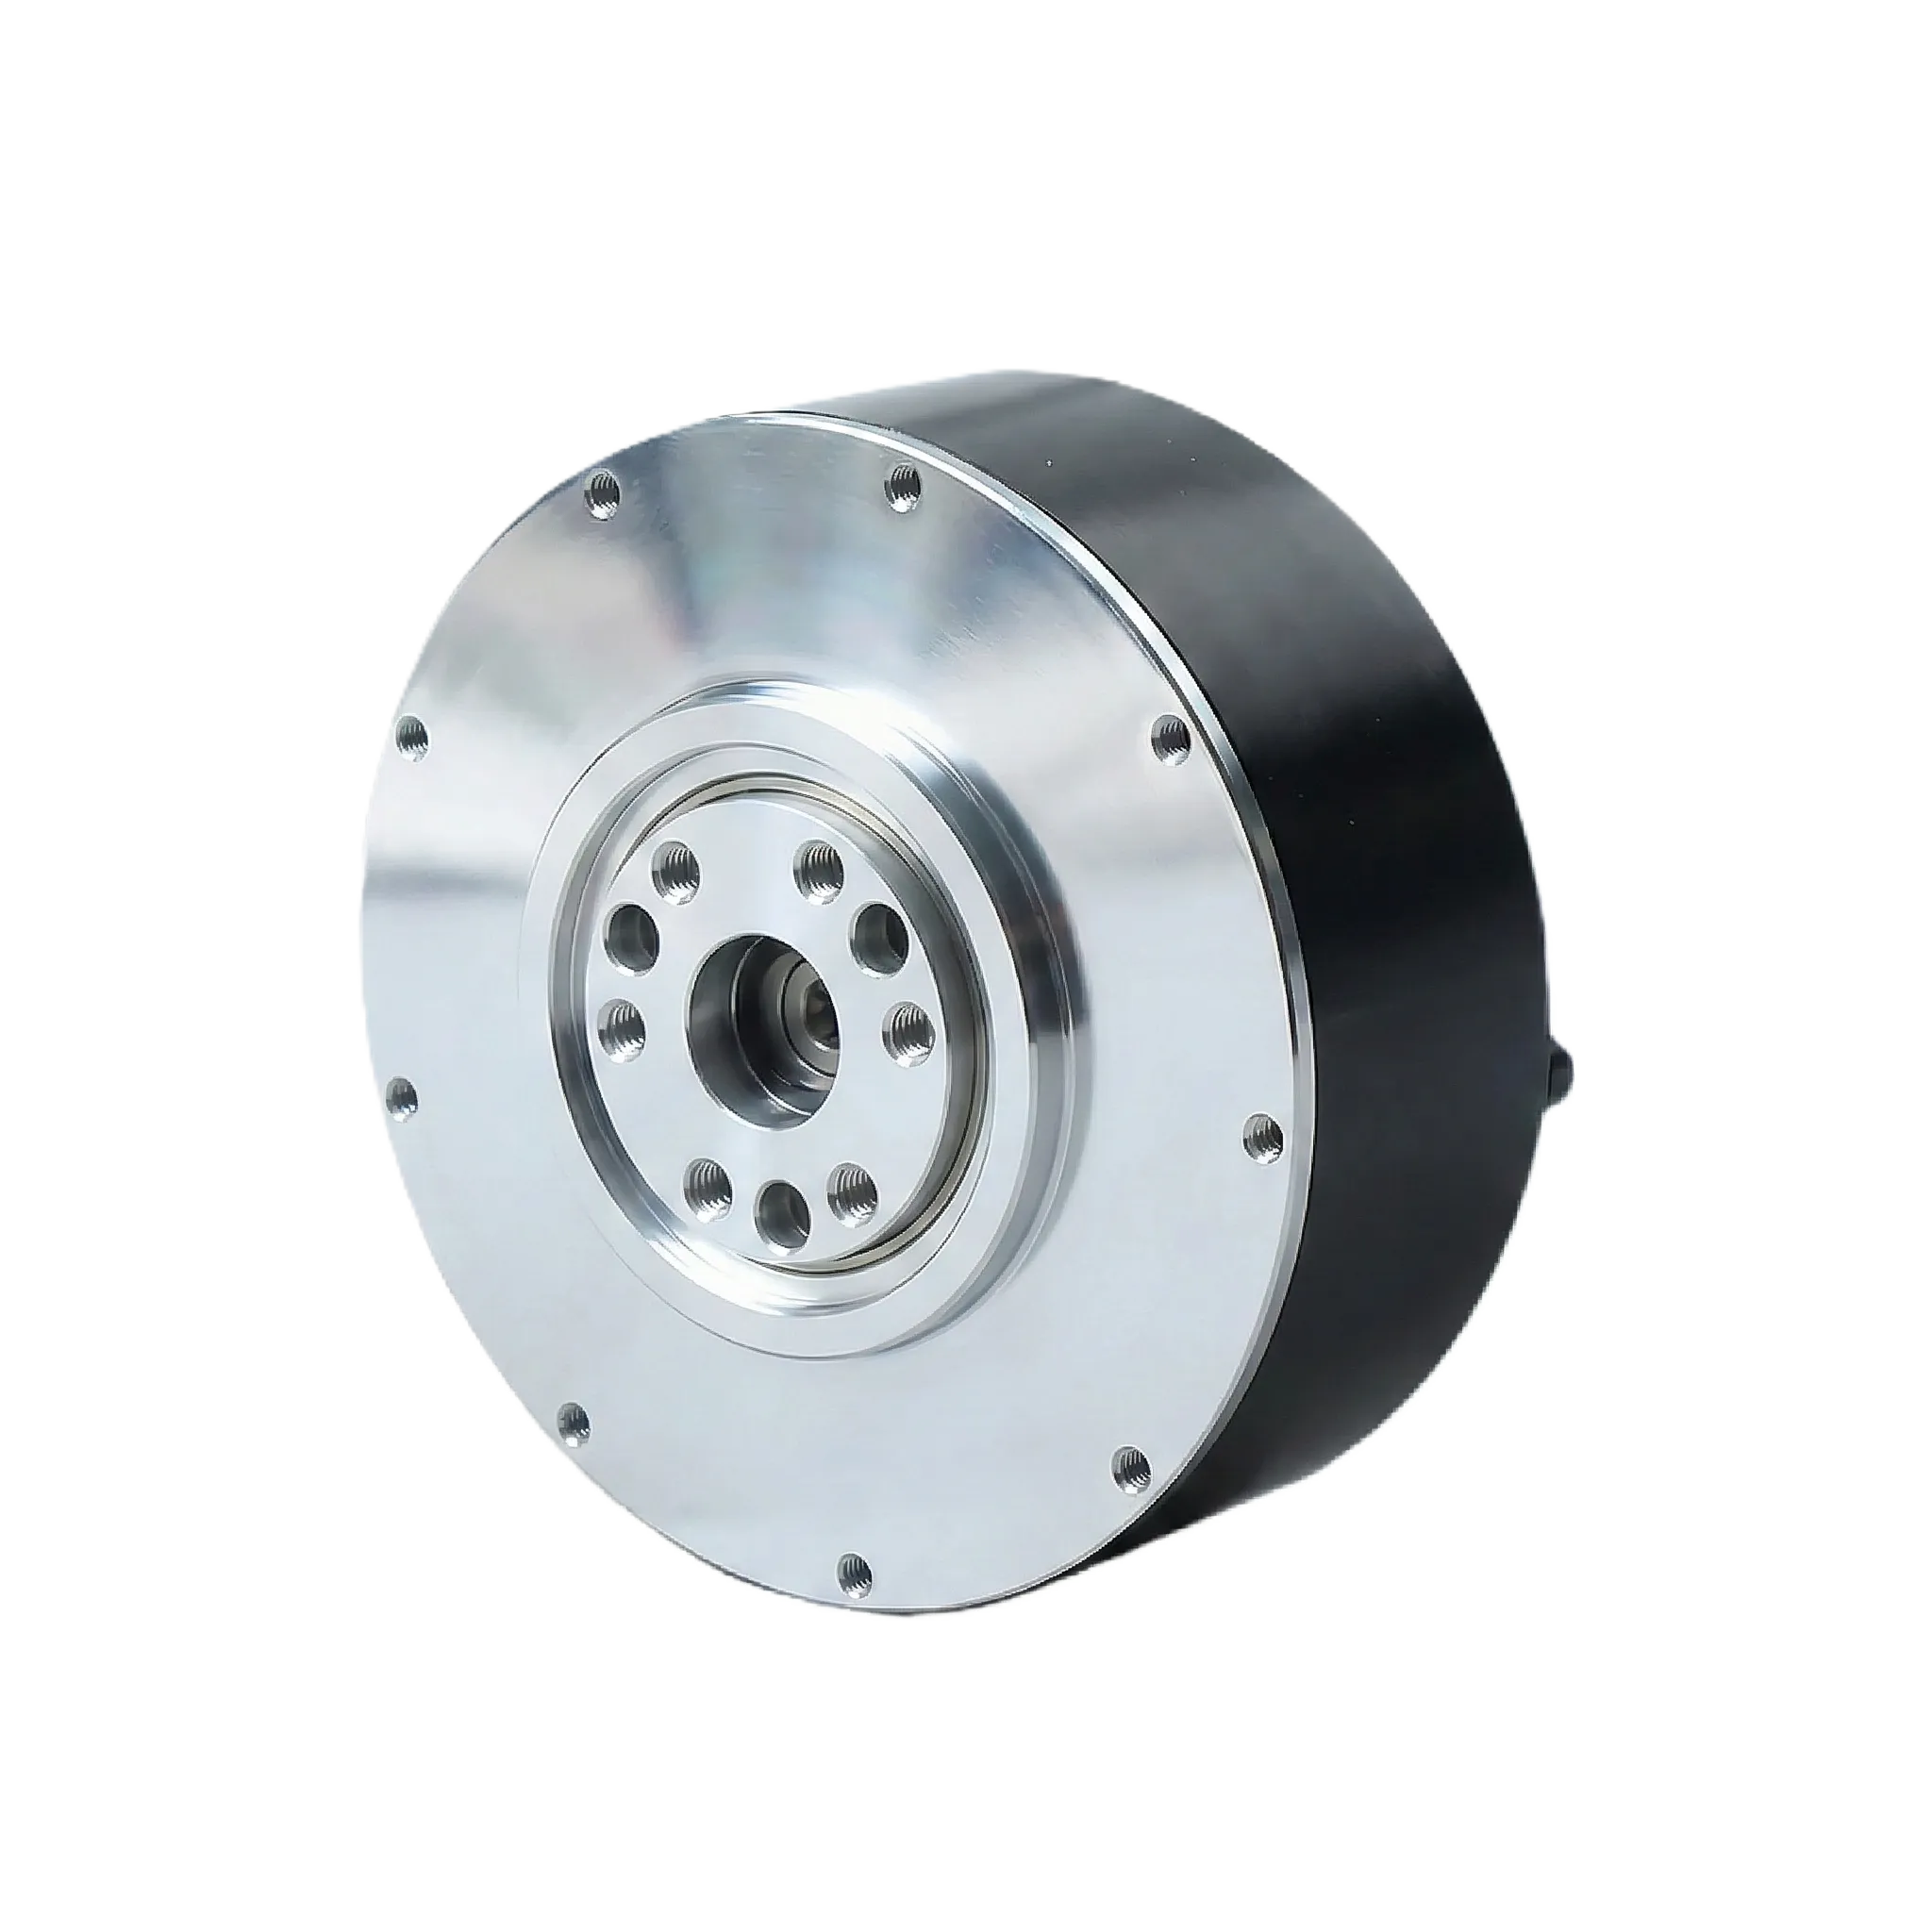
ZHR-P05 Micro integrated planetary reduction joint motor module front view

ZHR-P05

Integrated QDD Actuator
Logo
Reduction
7.75 : 1
Weight
191g
Peak Torque
5.5 Nm
Mechanical Specifications
Model ZHR-P05
Pole / Phase 20 / 3
Drive Method FOC
Reduction Ratio 7.75 : 1
Encoder Type Magnetic Encoder (2 pcs)
Performance & Electrical
Operation Voltage Range 15 - 60 VDC
Rated Voltage 48 V
Rated Output Power 17 W ± 10%
Rated Torque 1.6 N.m
Peak Torque 5.5 N.m
Speed & Current
No-load Speed 480 rpm ± 10%
No-load Current 0.14 Arms ± 10%
Rated Load Speed 100 rpm ± 10%
Rated Load Phase Current 2.4 Apk ± 10%
Peak Phase Current 11 Apk ± 10%
Motor Constants
Line Resistance 2.72 Ω ± 10%
Inductance 0.813 mH ± 10%
Back-EMF 7.4 Vrms/krpm ± 10%
Torque Constant 0.94 N.m/Arms

Dimension Drawing

ZHR-P05 Planetary Gearbox Actuator Dimensional Drawing
ZHR-P14 Micro integrated planetary reduction joint motor module front view

ZHR-P14

Integrated QDD Actuator

Logo
Reduction
10 : 1
Weight
310g ± 3g
Peak Torque
14 Nm
Mechanical Specifications
Model ZHR-P14
Pole / Phase 28 / 3
Drive Method FOC
Reduction Ratio 10 : 1
Encoder Type Magnetic Encoder (2 pcs)
Performance & Electrical
Operation Voltage Range 24 - 60 VDC
Rated Voltage 48 V
Rated Output Power 50 W ± 10%
Rated Torque 5 N.m
Peak Torque 14 N.m
Speed & Current
No-load Speed 315 rpm ± 10%
No-load Current 0.5 Arms
Rated Load Speed 100 rpm ± 10%
Rated Load Phase Current 4.7 Apk ± 10%
Peak Phase Current 15.5 Apk ± 10%
Motor Constants
Line Resistance 1.5 Ω ± 10%
Inductance 750 ± 20% μH
Back-EMF 0.095 Vrms/rpm ± 10%
Torque Constant 1.48 N.m/Arms

Dimension Drawing

ZHR-P14 Planetary Gearbox Actuator Dimensional Drawing
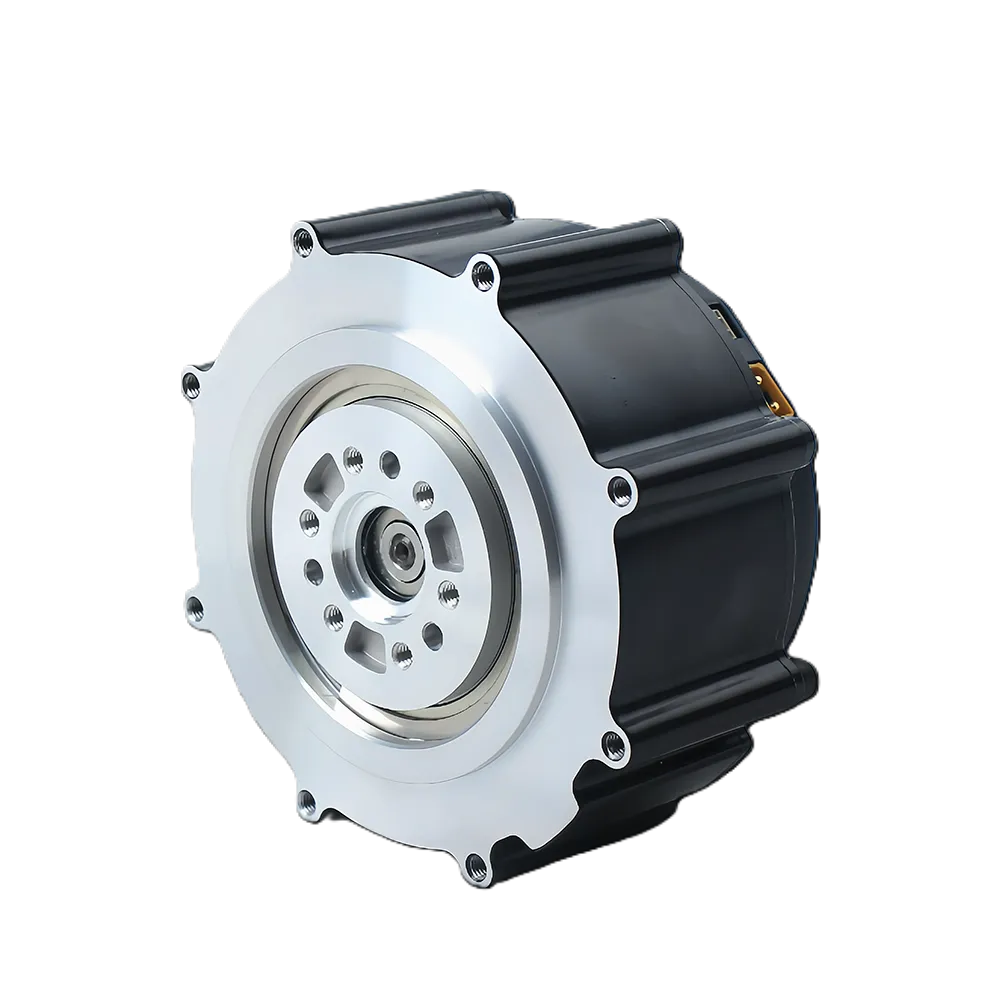
ZHR-P17 Micro integrated planetary reduction joint motor module front view

ZHR-P17

Integrated QDD Actuator

Logo
Reduction
7.75 : 1
Weight
380g ± 3g
Peak Torque
17 Nm
Two P17 configurations are available. This table covers 48 V / 2 encoders, from Catalog B, page 3 (24–60 V range; 410/100 rpm no-load/rated-load). The 36 V / 1 encoder configuration, from Catalog A, page 4, uses a 24–48 V range and 315/275 rpm no-load/rated-load. All listed speeds: ± 10%. Specify the chosen configuration when ordering; document revision numbers require confirmation. Compare P17 configurations.
Mechanical Specifications
Model ZHR-P17
Pole / Phase 28 / 3
Drive Method FOC
Reduction Ratio 7.75 : 1
Encoder Type Magnetic Encoder (2 pcs)
Performance & Electrical
Operation Voltage Range 24 - 60 VDC
Rated Voltage 48 V
Rated Output Power 60 W ± 10%
Rated Torque 6 N.m
Peak Torque 17 N.m
Speed & Current
No-load Speed 410 rpm ± 10%
No-load Current 0.5 Arms
Rated Load Speed 100 rpm ± 10%
Rated Load Phase Current 7 Apk ± 10%
Peak Phase Current 23 Apk ± 10%
Motor Constants
Line Resistance 0.55 Ω
Inductance 486 ± 20% μH
Back-EMF 0.096 Vrms/rpm ± 10%
Torque Constant 1.22 N.m/Arms

Dimension Drawing

ZHR-P17 Planetary Gearbox Actuator Dimensional Drawing
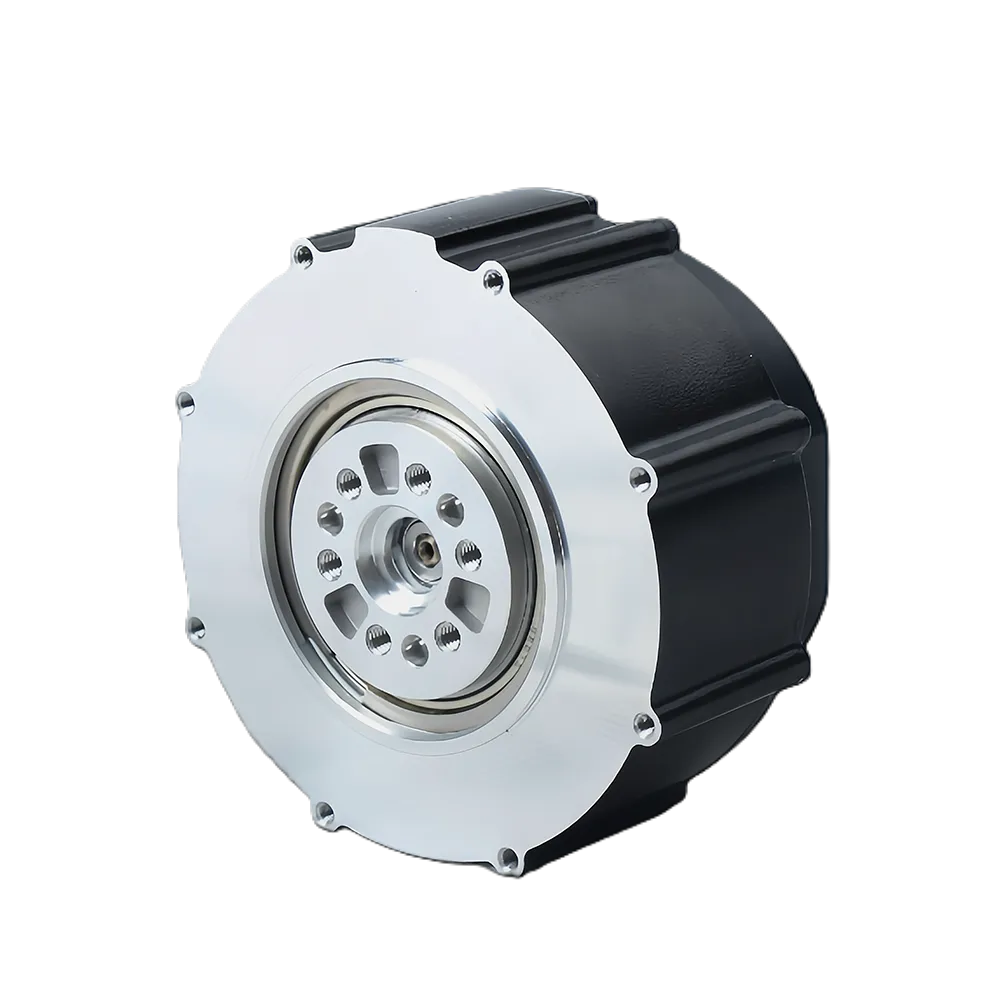
ZHR-P36 Micro integrated planetary reduction joint motor module front view

ZHR-P36

Integrated QDD Actuator

Logo
Reduction
9 : 1
Weight
621g
Peak Torque
36 Nm
Mechanical Specifications
Model ZHR-P36
Pole / Phase 28 / 3
Drive Method FOC
Reduction Ratio 9 : 1
Encoder Type Magnetic Encoder (2 pcs)
Performance & Electrical
Operation Voltage Range 15 - 60 VDC
Rated Voltage 48 V
Rated Output Power 115 W ± 10%
Rated Torque 11 N.m
Peak Torque 36 N.m
Speed & Current
No-load Speed 480 rpm ± 10%
No-load Current 0.98 Arms ± 10%
Rated Load Speed 100 rpm ± 10%
Rated Load Phase Current 14.3 Apk ± 10%
Peak Phase Current 57 Apk ± 10%
Motor Constants
Line Resistance 0.23 Ω ± 10%
Inductance 0.165 mH ± 10%
Back-EMF 7.6 Vrms/krpm ± 10%
Torque Constant 1.1 N.m/Arms

Dimension Drawing

ZHR-P36 Planetary Gearbox Actuator Dimensional Drawing
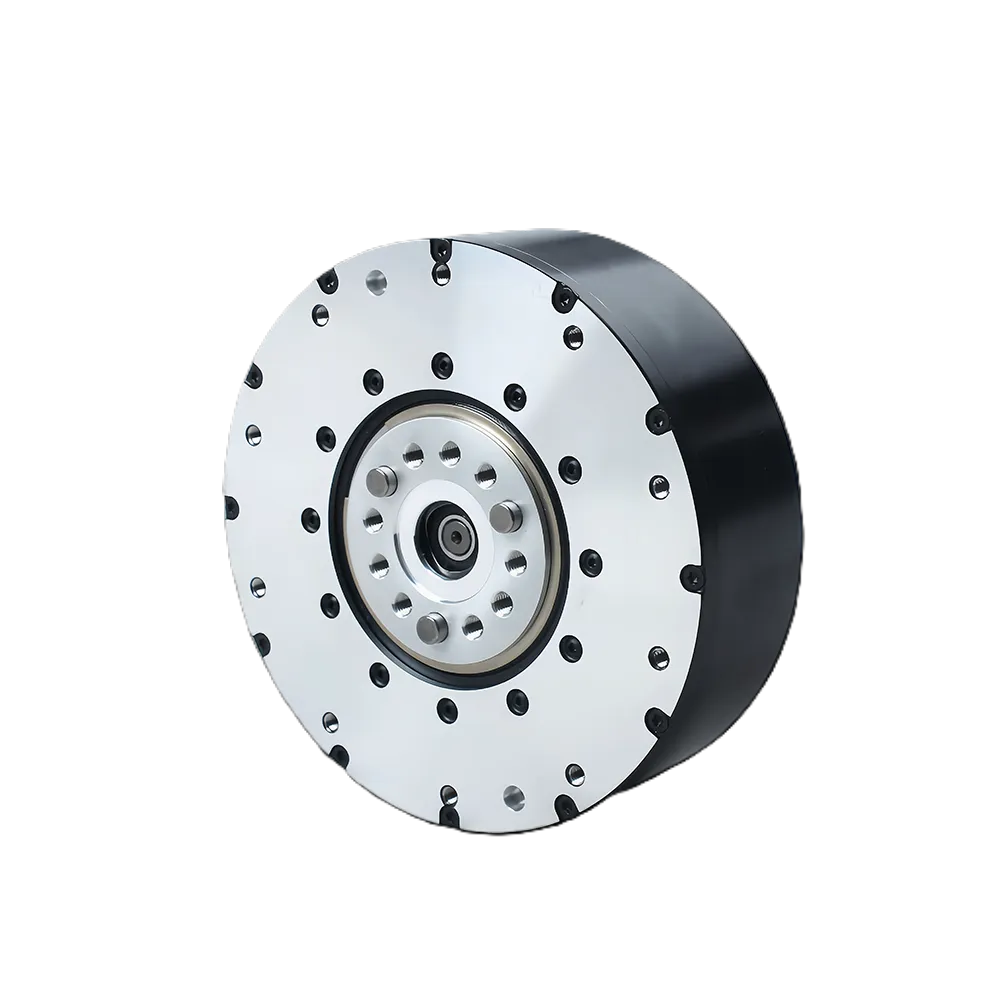
ZHR-P60 Micro integrated planetary reduction joint motor module front view

ZHR-P60

Integrated QDD Actuator

Logo
Reduction
9 : 1
Weight
900g ± 20g
Peak Torque
60 Nm
Mechanical Specifications
Model ZHR-P60
Pole / Phase 42 / 3
Drive Method FOC
Communication Interface CAN only; native EtherCAT not supported
Reduction Ratio 9 : 1
Encoder Type Magnetic Encoder (2 pcs)
Performance & Electrical
Operation Voltage Range 15 - 60 VDC
Rated Voltage 48 V
Rated Output Power 210 W ± 10%
Rated Torque 20 N.m
Peak Torque 60 N.m
Speed & Current
No-load Speed 195 rpm ± 10%
No-load Current 0.6 Arms ± 10%
Rated Load Speed 100 rpm ± 10%
Rated Load Phase Current 13 Apk ± 10%
Peak Phase Current 43 Apk ± 10%
Motor Constants
Line Resistance 0.39 Ω ± 10%
Inductance 0.275 mH ± 10%
Back-EMF 17 Vrms/krpm ± 10%
Torque Constant 2.36 N.m/Arms

Dimension Drawing

ZHR-P60 Planetary Gearbox Actuator Dimensional Drawing
ZHR-P120 Micro integrated planetary reduction joint motor module front view

ZHR-P120

Integrated QDD Actuator

Logo
Reduction
9 : 1
Weight
1420g ± 20g
Peak Torque
120 Nm
Mechanical Specifications
Model ZHR-P120
Pole / Phase 42 / 3
Drive Method FOC
Reduction Ratio 9 : 1
Encoder Type Magnetic Encoder (2 pcs)
Performance & Electrical
Operation Voltage Range 15 - 60 VDC
Rated Voltage 48 V
Rated Output Power 420 W ± 10%
Rated Torque 40 N.m
Peak Torque 120 N.m
Speed & Current
No-load Speed 200 rpm ± 10%
No-load Current 0.7 Arms ± 10%
Rated Load Speed 100 rpm ± 10%
Rated Load Phase Current 27 Apk ± 10%
Peak Phase Current 90 Apk ± 10%
Motor Constants
Line Resistance 0.16 Ω ± 10%
Inductance 0.211 mH ± 10%
Back-EMF 16.9 Vrms/krpm ± 10%
Torque Constant 2.1 N.m/Arms

Dimension Drawing

ZHR-P120 Planetary Gearbox Actuator Dimensional Drawing
Datasheet FAQ

ZHR-P Planetary Joint Actuator Datasheet FAQ

Frequently asked questions regarding torque curves, electrical ratings, mechanical dimensions, and sampling lead times.

What models and performance ratings are covered in the ZHR-P planetary spec sheets? ▾

The ZHR-P specification sheets cover models P05, P14, P17, P36, P60, and P120. Peak output torques span from 4.5 Nm up to 120 Nm with backlash between 3 and 10 arcmin, offering high backdrivability and dynamic impact tolerance.

When is the ZHR-P planetary joint preferred over the ZHR-H harmonic joint? ▾

ZHR-P planetary actuators excel in dynamic, high-speed, and impact-heavy robot joints—such as quadruped robot legs, humanoid knee/hip joints, and active exoskeletons—where mechanical backdrivability and shock absorption are critical design priorities.

What communication interfaces are supported across the ZHR-P series? ▾

Models P05, P14, P17, and P36 support CAN 2.0B and CANopen protocols. P60 operates natively on CAN bus, while P120 supports CAN/CANopen with optional RS-485 for advanced diagnostics and closed-loop telemetry.

What are the sample delivery times and minimum order quantities? ▾

Standard catalog models ship within 3–5 business days for engineering prototypes with an MOQ of 1 unit. Custom planetary gear stages or tailored output shafts require 2–3 weeks.