Unleash creativity with the revolutionary Xiaomi CyberGear Micro joint motor. A high-performance, compact joint module designed for the future of Robot Actuators and Collaborative Robots. Published features include 12 Nm peak torque, an 18-bit magnetic encoder, FOC control and a quick-release connector design. Peak torque is not a continuous-duty rating; confirm rated operating conditions, allowable peak duration and the actual unit configuration.
Available for B2B pre-order and procurement requests. Request a quote for pricing, MOQ, lead time, and integration support.
Quick answer: Compare CyberGear's published 12 Nm peak torque with your load profile, then confirm continuous-duty capability, thermal conditions, interface and mounting fit. Do not assume a ZHR replacement has the same connector, protocol or mechanical envelope. For alternatives, review the CyberGear alternative guide, integrated servo joint module guide, and ZHR-P servo joint modules.
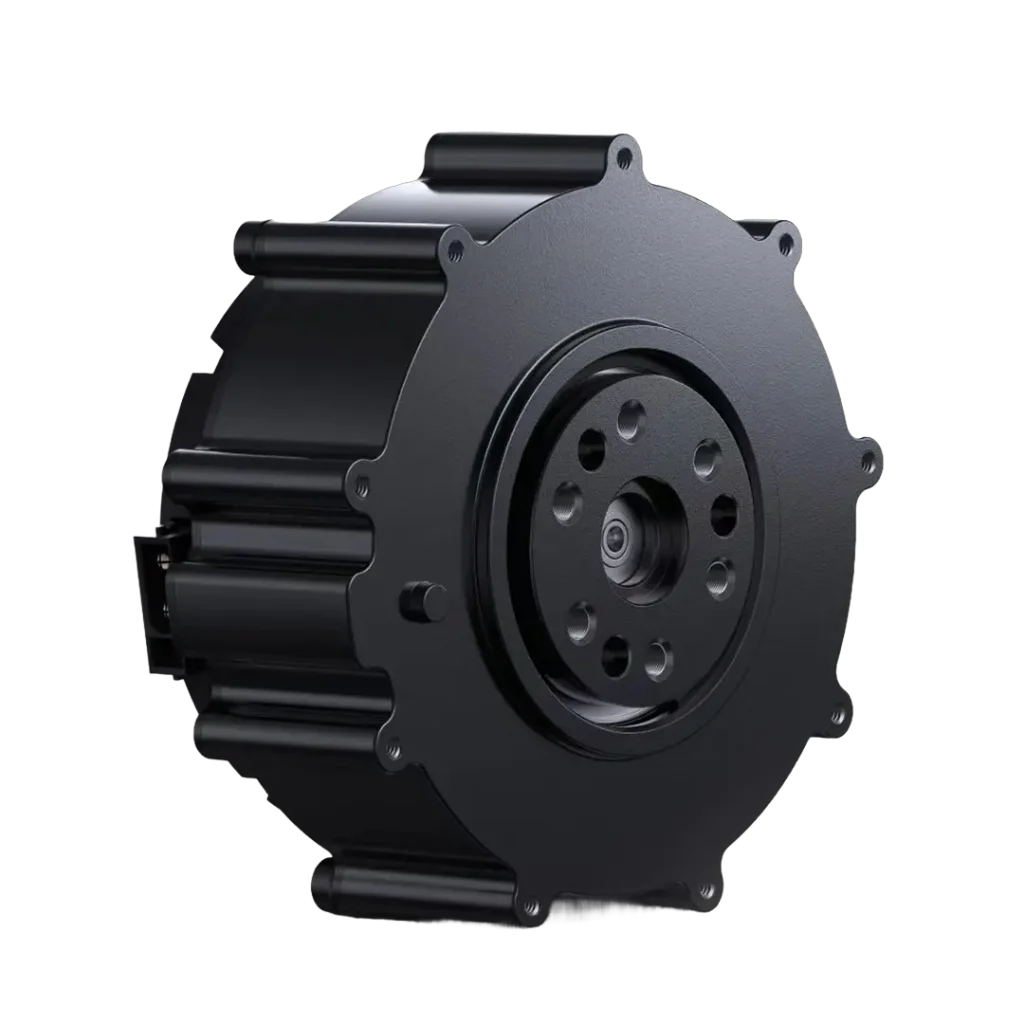
Gear assembly adopts high precision processing technology with complex surface treatment for smooth operation.
Stator and rotor adopt high quality materials with iron core plastic coating process for higher durability.
Published peak torque is 12 Nm. Verify continuous-duty limits, peak duration, speed and cooling conditions. A density comparison also needs the same assembly-mass boundary.
The outgoing plug adopts quick release design. Convenient for modular use and fast maintenance.
Optimized FOC motor control algorithm ensures accurate and fast closed-loop speed and position control.
Self-developed temperature monitoring system and protection algorithm makes operation safer and more reliable.
The CyberGear joint motor is designed with integration in mind. Its flat, lightweight form factor allows it to be easily embedded as a joint module into robotic limbs, exoskeletons, and other precision Robot Actuators without adding unnecessary bulk.
From the high-grade magnetic steel to the specialized coatings on the iron core, every component is optimized for efficiency and longevity. The 18-bit magnetic encoder specifies resolution; output positioning accuracy must be assessed separately under the intended load.
A peak torque figure does not establish sustained output at your duty cycle. Confirm the current model documentation, thermal limits, supply requirements, mounting dimensions, connector pinout and controller protocol before ordering. If moving to another actuator, compare mechanical and software integration work rather than assuming a compatible replacement.
Review actuator replacement criteria Compare planetary joint options
Learn more about micro motors, torque density, and actuator integration.
Master actuator selection for humanoid robots, cobots, and exoskeletons. Data-driven comparison of frameless vs housed motors.
Technical ReferenceUnderstanding Nm/kg ratio, industry benchmarks, calculation methods, and optimization strategies for compact joint motors.
Technical Deep DiveDefinitive breakdown of strain wave kinematics. Understand how zero-backlash transmission works in compact actuators.