Supplier qualification for robotics buyers
About ZHR Motor
ZHR Motor is the robotics motion product brand of Shenzhen HZN Intelligent Control Co., Ltd., providing integrated harmonic servo joints (ZHR-H), planetary quasi-direct-drive modules (ZHR-P), micro linear servo electric cylinders (FT/DE), and high-force brushless electric cylinders (ZHR-BC) for humanoid robots, quadrupeds, precision medical tools, and industrial automated equipment.
- Legal entity
- Shenzhen HZN Intelligent Control Co., Ltd.
- Public evidence
- Spec sheets, quality testing, certificates, policies
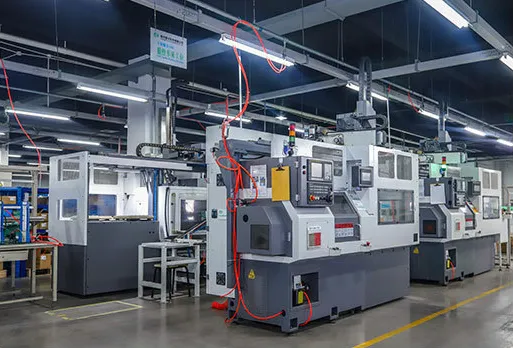
Supplier qualification, engineering review, and quality evidence in one place.
Use this page to verify company identity, public documentation, quality references, and the correct contact path before sharing RFQ details.
Certification evidence
Quality and compliance documents
Public certificate references are kept visible for overseas supplier qualification, internal sourcing review, and early project screening.
View Certification Page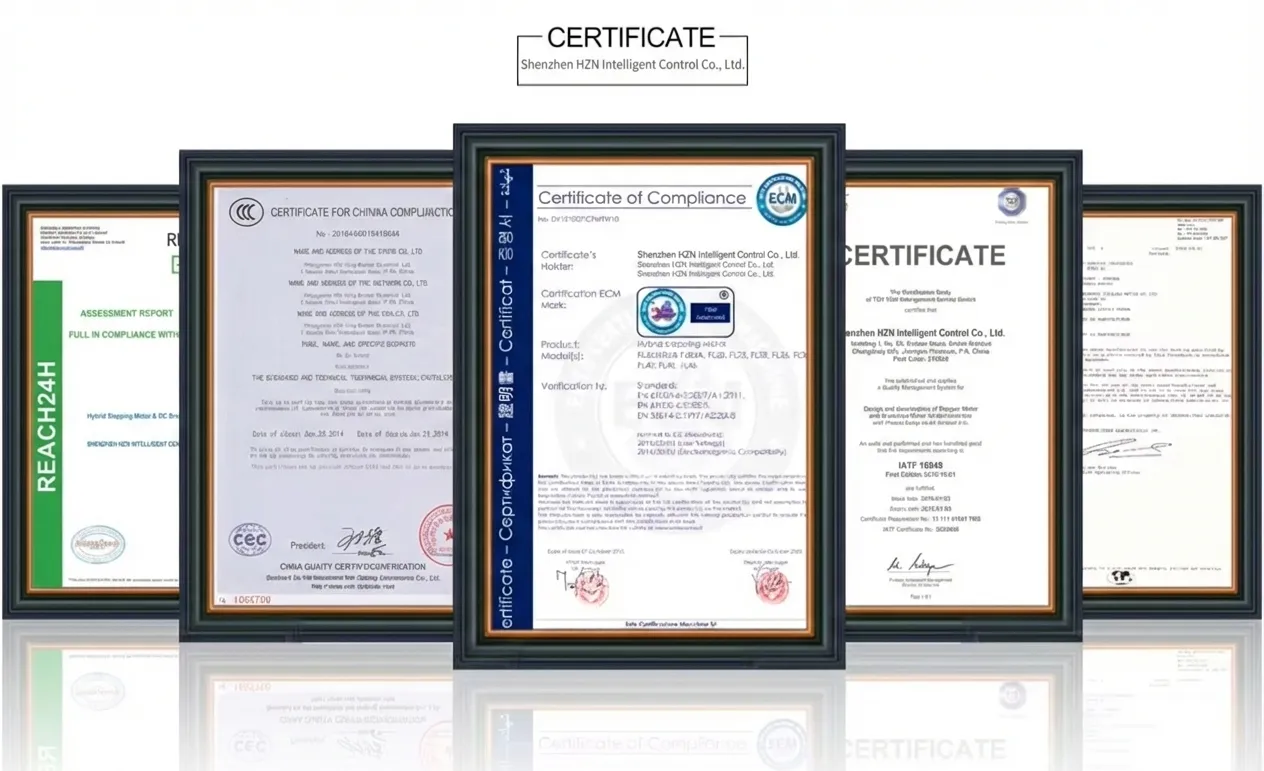
What buyers can verify
Company identity and contact path
A serious B2B inquiry should not depend on vague claims. This page gathers the practical trust signals that overseas engineering, sourcing, and founder teams usually check before sending drawings or project details.
- Legal company name
- Shenzhen HZN Intelligent Control Co., Ltd.
- Brand / website
- ZHR Motor / Zhinno Robotics, robotics.zhinno.com
- Office
- Block B, Building 2, Tian'an Digital Park, Longgang District, Shenzhen 518116, China
- infozhinno.com
- +86 186 1707 5295
Product families
What ZHR Motor supplies
The fastest route to trust is giving engineers enough context to disqualify the wrong product early. Each product family links directly to interactive spec explorers, 3D CAD files, and technical datasheets.
ZHR-H Harmonic Joint Modules
Integrated strain wave reducer, dual 18-bit encoders, and FOC driver. 5–91 Nm rated / 15–210 Nm peak torque with <20 arcsec backlash for zero-backlash robotic arms.
ZHR-P Planetary Joint Modules
Quasi-direct-drive planetary actuators offering 1.6–40 Nm continuous / 5.5–120 Nm peak torque. High dynamic bandwidth and transparent backdrivability for legged and mobile robots.
Micro Servo Electric Cylinders (FT/DE)
Planetary roller screw actuators providing 20–600 N thrust with ±0.002 mm repeatability and 2–12 mm stroke. Built-in RS485 for coating adjustment and dexterous robotic hands.
ZHR-BC High-Force Brushless Servo Electric Cylinders
Compact brushless linear cylinders replacing pneumatic cylinders. Up to 300 N stall force, 25–30 mm stroke, and ±0.02 mm multi-point positioning in an ultra-compact Ø13–Ø16 mm body.
Xiaomi CyberGear Evaluation Option
Compact 12 Nm peak torque robotic joint motor with integrated 18-bit magnetic encoder and CAN bus control. Ideal for prototype evaluation and academic robotics benchmarks.
Actuator Selector & 3D CAD Library
Interactively compare torque, gear ratios, stroke, and mass across all ZHR joint modules and electric cylinders. Instant access to STEP / STP 3D models and spec sheets.
Engineering support
What we confirm before quotation
Good suppliers reduce uncertainty before price discussion. For actuator projects, the important question is not only whether a model exists, but whether the exact torque, envelope, interface, sample path, and documentation fit your build.
Send Project RequirementsMechanical fit
Torque, peak torque, diameter, length, mass, mounting envelope, drawing request, shaft and flange constraints.
Electrical fit
Voltage, current, driver/integrated drive needs, cable route, connector requirements, and thermal margin.
Control interface
CAN, RS485, EtherCAT, CANopen, or CAN FD must be confirmed by exact model and configuration.
Commercial path
Sample availability, MOQ, lead time, shipping destination, and documentation needed for internal supplier approval.
Evidence links
Public pages that support supplier qualification
These links are intentionally visible. They help engineers, sourcing teams, and AI search systems ground answers in verifiable pages instead of relying only on sales copy.
Honest boundaries
What must be confirmed by model
Trust increases when the page says where confirmation is required. For robotics buyers, this prevents mismatched samples, wrong protocol assumptions, and unnecessary back-and-forth.
Communication protocols are model-specific
Do not assume a protocol from a product family name. Confirm the exact model and configuration before RFQ, sample purchase, or controller integration.
ZHR-P60 communication boundary
ZHR-P60 is CAN only and does not support native EtherCAT. EtherCAT requirements should be checked against the correct model and configuration.
Harmonic vs. Planetary selection
Zero-backlash precision trajectory axes require ZHR-H strain wave modules. Dynamic legged robotics requiring shock tolerance and backdrivability use ZHR-P quasi-direct-drive units.
Linear actuator stroke & force envelope
FT/DE models cover micro-stroke (2–12 mm) with ±0.002 mm repeatability. ZHR-BC models cover longer stroke (25–30 mm) with up to 300 N stall force to replace miniature pneumatic cylinders.
Samples, MOQ, and lead time
Sample MOQ is 1 unit. Standard in-stock prototypes dispatch in 3–5 business days via DHL/FedEx Express; customized configurations or trial batches dispatch in 2–3 weeks following engineering review.
Ready for supplier review
Send torque, size, protocol, and quantity requirements.
For faster response, include the robot joint or machine axis, target torque, speed, voltage, preferred communication interface, envelope constraints, and expected sample or pilot quantity.