Product catalog
Catalog A page 4 describes the available 36 V single-encoder configuration. Catalog B page 3 describes the available 48 V dual-encoder configuration. Use the data for your chosen configuration.
Open ZHR-P17 catalog page ↗Integrated motion · Planetary joint series
ZHR-P17 combines a planetary transmission and servo drive in a robot joint module with 6 Nm rated torque and 17 Nm peak torque. Explore the actual product, mounting drawing and detailed specifications below.
Model-specific configuration review · Direct engineering contact
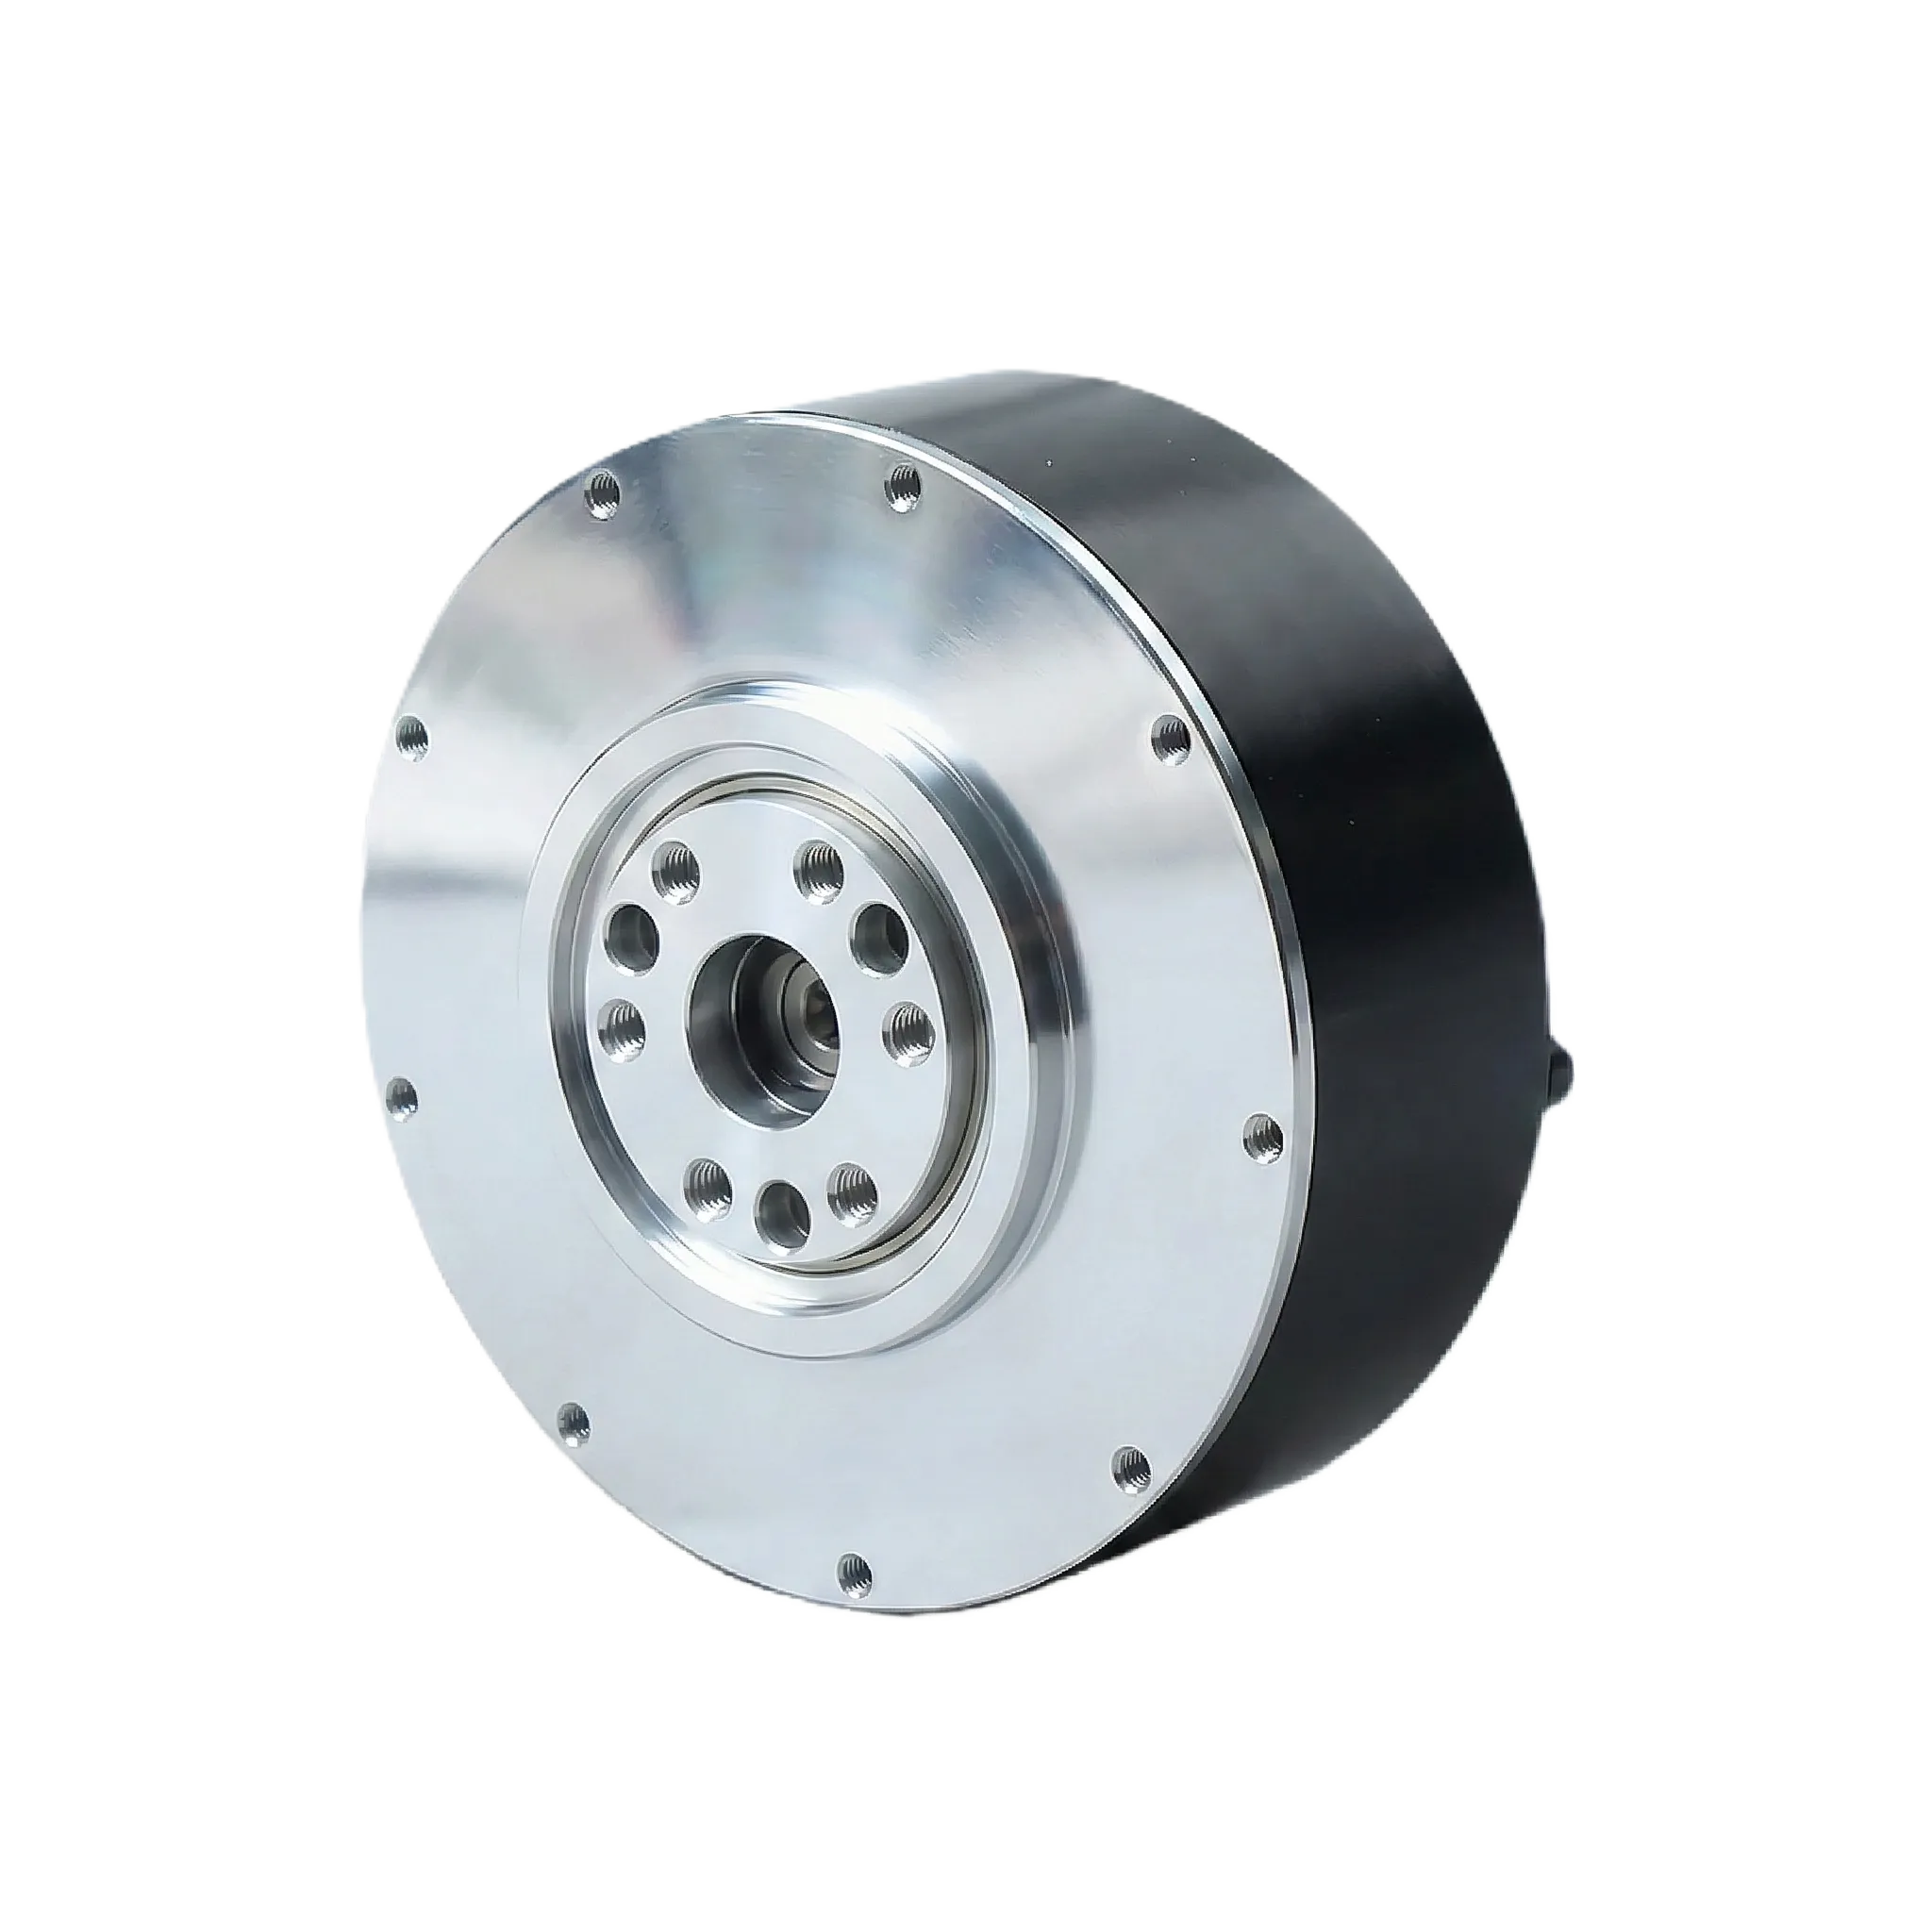
Quick answer: consider ZHR-P17 for compact dynamic motion where the mechanical envelope and application conditions fit the selected model. Validate the complete duty cycle, mechanical envelope and interface with engineering before release.
ZHR-P17 sits between ZHR-P14 and ZHR-P36 in the published torque range. Compare its 6 Nm rated and 17 Nm peak torque with your load requirements rather than selecting by the model number alone.
Encoder, backlash and communication configuration are model-specific. ZHR-P60 is CAN only and does not support native EtherCAT.
Torque values are model-specific. Confirm the duty cycle, thermal conditions, interface and mechanical drawing before design-in.
ZHR-P17 is available in two configurations: 36 V with one magnetic encoder and 48 V with two magnetic encoders. Select and state the configuration in your inquiry; document revision numbers still require confirmation. Compare the two P17 configurations and request engineering confirmation.

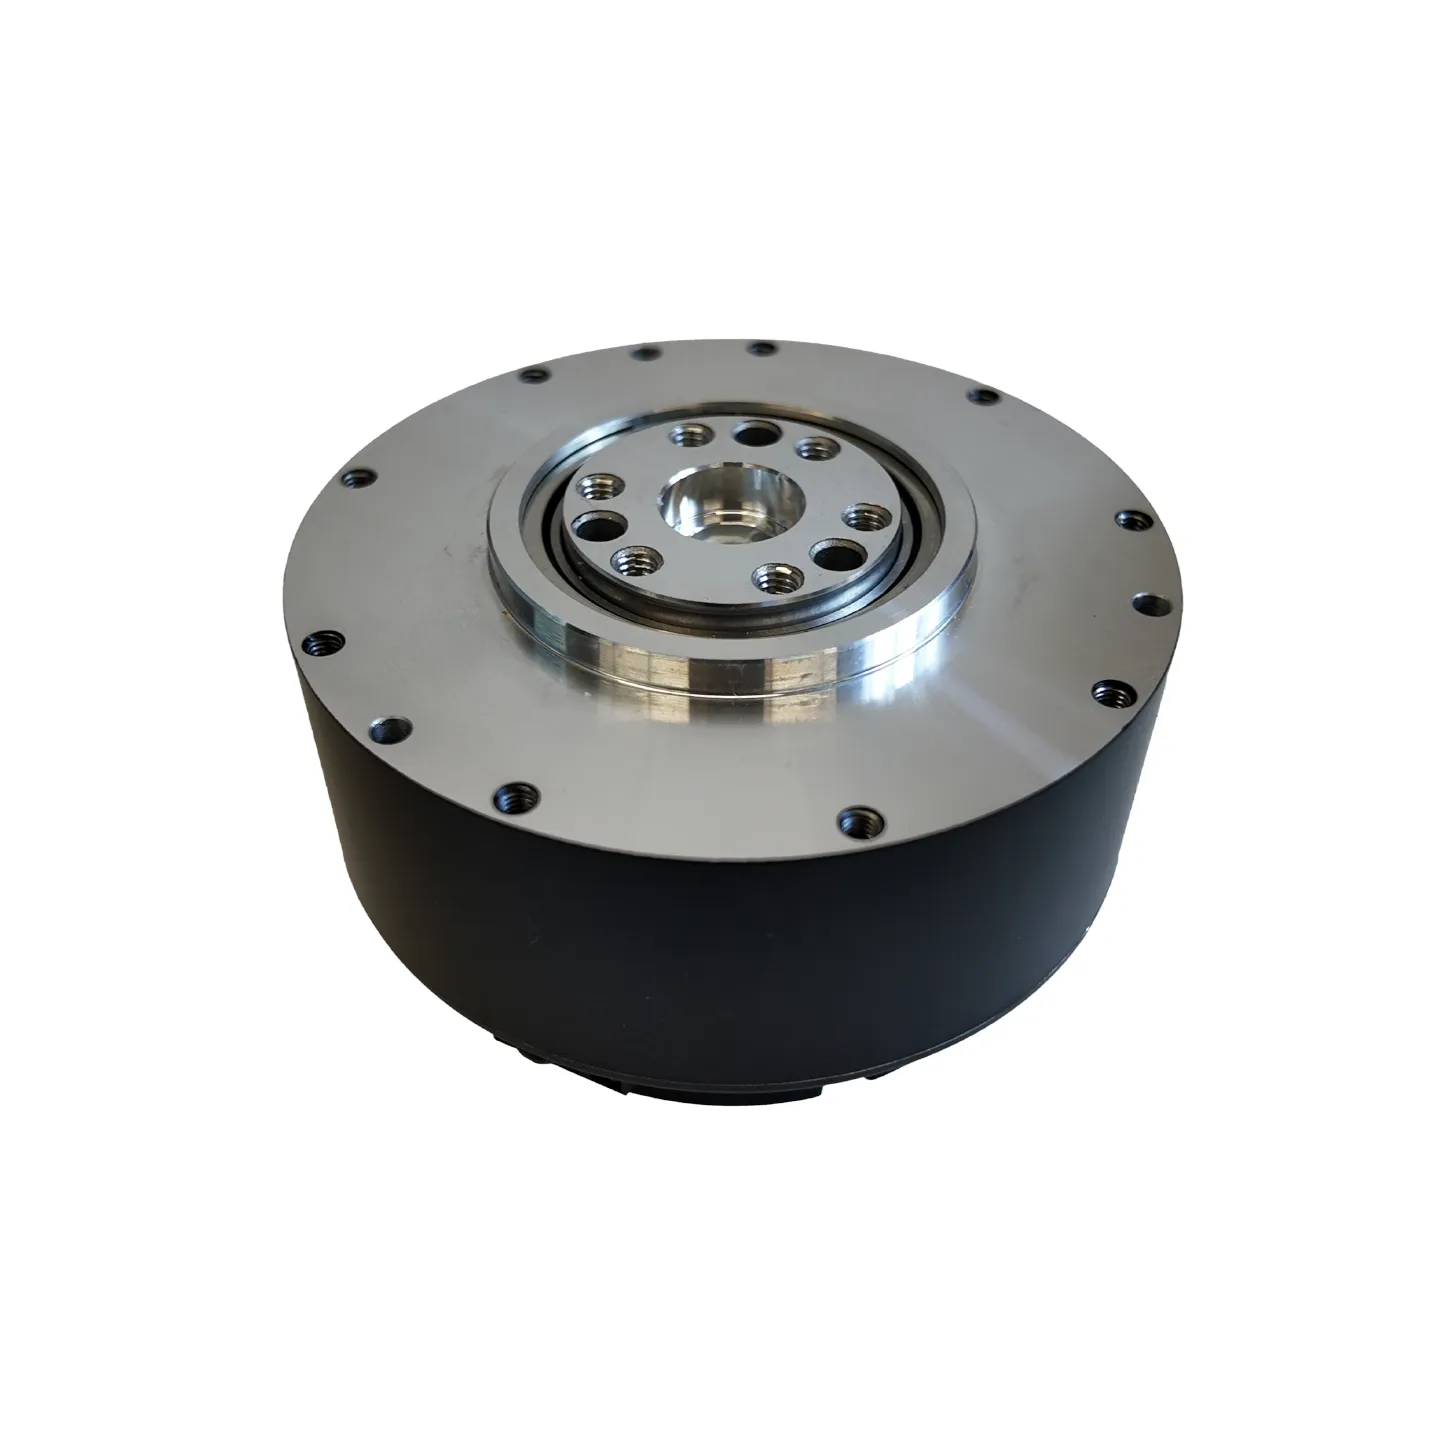
Select an image to inspect the original product photograph in a new tab.
Choose the 36 V single-encoder or 48 V dual-encoder configuration, then confirm the matching document revision before design-in.
Download Catalog (PDF) ↓Catalog A, page 4: 36 V rated, 24–48 V range, 1 encoder, 315 rpm no-load and 275 rpm rated-load speed (both ± 10%). Catalog B, page 3: 48 V rated, 24–60 V range, 2 encoders, 410 rpm no-load and 100 rpm rated-load speed (both ± 10%). Both configurations are available. Specify the chosen voltage and encoder configuration when requesting a quote; document revision numbers remain to be confirmed. Compare configuration data before selection.
| Parameter | Published value |
|---|---|
| Rated torque | 6 Nm |
| Peak torque | 17 Nm |
| Weight | 380 g ± 3 g |
| Reduction Ratio | 7.75 : 1 |
| Drive Method | FOC |
| Rated Output Power | 60 W ± 10% |
| Communication interface | Confirm the interface and configuration with engineering before design-in. |
Communication boundary: Communication: model-specific; contact engineering to confirm the interface before design-in. ZHR-P60 is CAN only and does not support native EtherCAT.
Inspect the model-specific mounting interfaces before designing the mating parts.
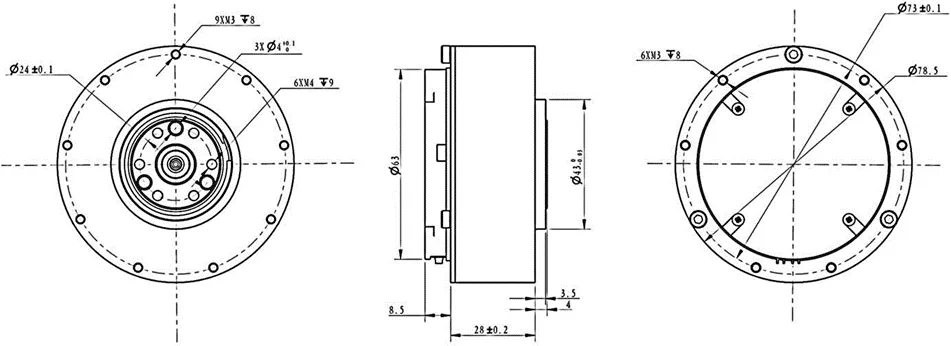
Use the series specification page for the current public drawings and data. Request model-specific documents, configuration confirmation and quotation with your application conditions.
Catalog A page 4 describes the available 36 V single-encoder configuration. Catalog B page 3 describes the available 48 V dual-encoder configuration. Use the data for your chosen configuration.
Open ZHR-P17 catalog page ↗Check the current series documentation alongside the model drawing and comparison data.
View series spec sheets →Ask for the current ZHR-P17 STEP model, interface confirmation and quotation for your configuration.
Request engineering review for ZHR-P17 →Compare published ratings first, then validate speed, packaging and controls. Weight alone does not determine application suitability.
| Model | Rated torque | Peak torque | Weight | Model page |
|---|---|---|---|---|
| ZHR-P05 | 1.6 Nm | 5.5 Nm | 191 g | View model details |
| ZHR-P14 | 5 Nm | 14 Nm | 310 g ± 3 g | View model details |
| ZHR-P17 | 6 Nm | 17 Nm | 380 g ± 3 g | Current model |
| ZHR-P36 | 11 Nm | 36 Nm | 621 g | View model details |
| ZHR-P60 | 20 Nm | 60 Nm | 900 g ± 20 g | View model details |
| ZHR-P120 | 40 Nm | 120 Nm | 1420 g ± 20 g | View model details |
ZHR-P17 is listed at 6 Nm rated torque and 17 Nm peak torque. Peak torque is not a continuous operating rating. Confirm allowable peak duration, duty cycle and thermal conditions with engineering.
Both configurations are available: 36 V rated with one magnetic encoder and a 24–48 V range (Catalog A page 4), or 48 V rated with two magnetic encoders and a 24–60 V range (Catalog B page 3). State your chosen configuration in the inquiry; document revision numbers still require confirmation. Compare the configuration data and confirm the actual unit with engineering before choosing its power supply.
Confirm the interface and configuration with engineering before design-in.
Use the model-specific dimensional drawing on this page and the linked specification catalog for initial layout. Request the current ZHR-P17 STEP model and configuration confirmation through the engineering RFQ link before releasing your mechanical design.
ZHR-P17 sits between ZHR-P14 and ZHR-P36 in the published torque range. Compare its 6 Nm rated and 17 Nm peak torque with your load requirements rather than selecting by the model number alone.
Specify either the 36 V single-encoder or 48 V dual-encoder configuration. Share your required torque and speed, duty cycle, supply voltage, control interface and target quantity. Your inquiry carries the ZHR-P17 reference so the engineering team can review the intended configuration.