Product catalog
Read the ZHR-P120 catalog page with electrical, mechanical and operating data.
Open ZHR-P120 catalog page ↗Integrated motion · Planetary joint series
ZHR-P120 combines a planetary transmission and servo drive in a robot joint module with 40 Nm rated torque and 120 Nm peak torque. Explore the actual product, mounting drawing and detailed specifications below.
Model-specific configuration review · Direct engineering contact
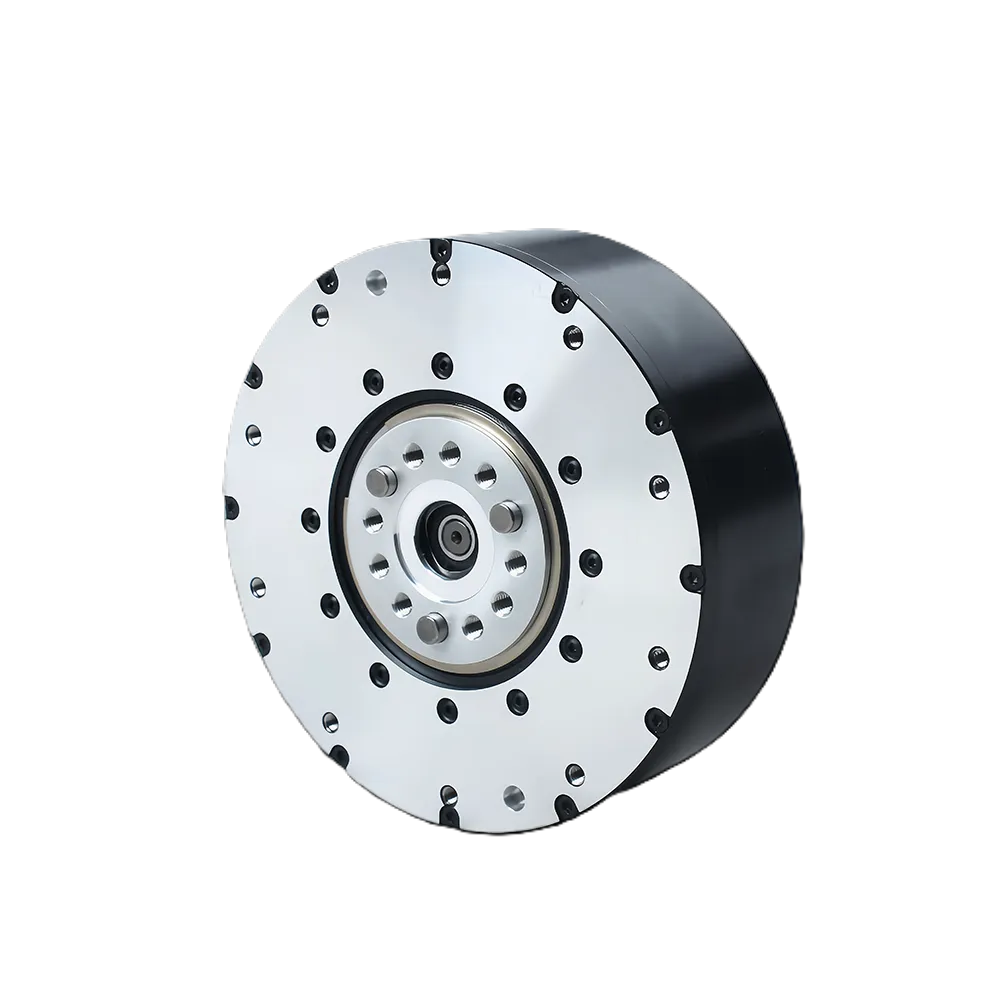
Quick answer: consider ZHR-P120 for compact dynamic motion where the mechanical envelope and application conditions fit the selected model. Validate the complete duty cycle, mechanical envelope and interface with engineering before release.
ZHR-P120 has the highest published rated and peak torque in this six-model ZHR-P comparison. Its 40 Nm rated and 120 Nm peak figures make it the upper torque option in this range; confirm the full duty cycle and mounting before selection.
Encoder, backlash and communication configuration are model-specific. ZHR-P60 is CAN only and does not support native EtherCAT.
Torque values are model-specific. Confirm the duty cycle, thermal conditions, interface and mechanical drawing before design-in.

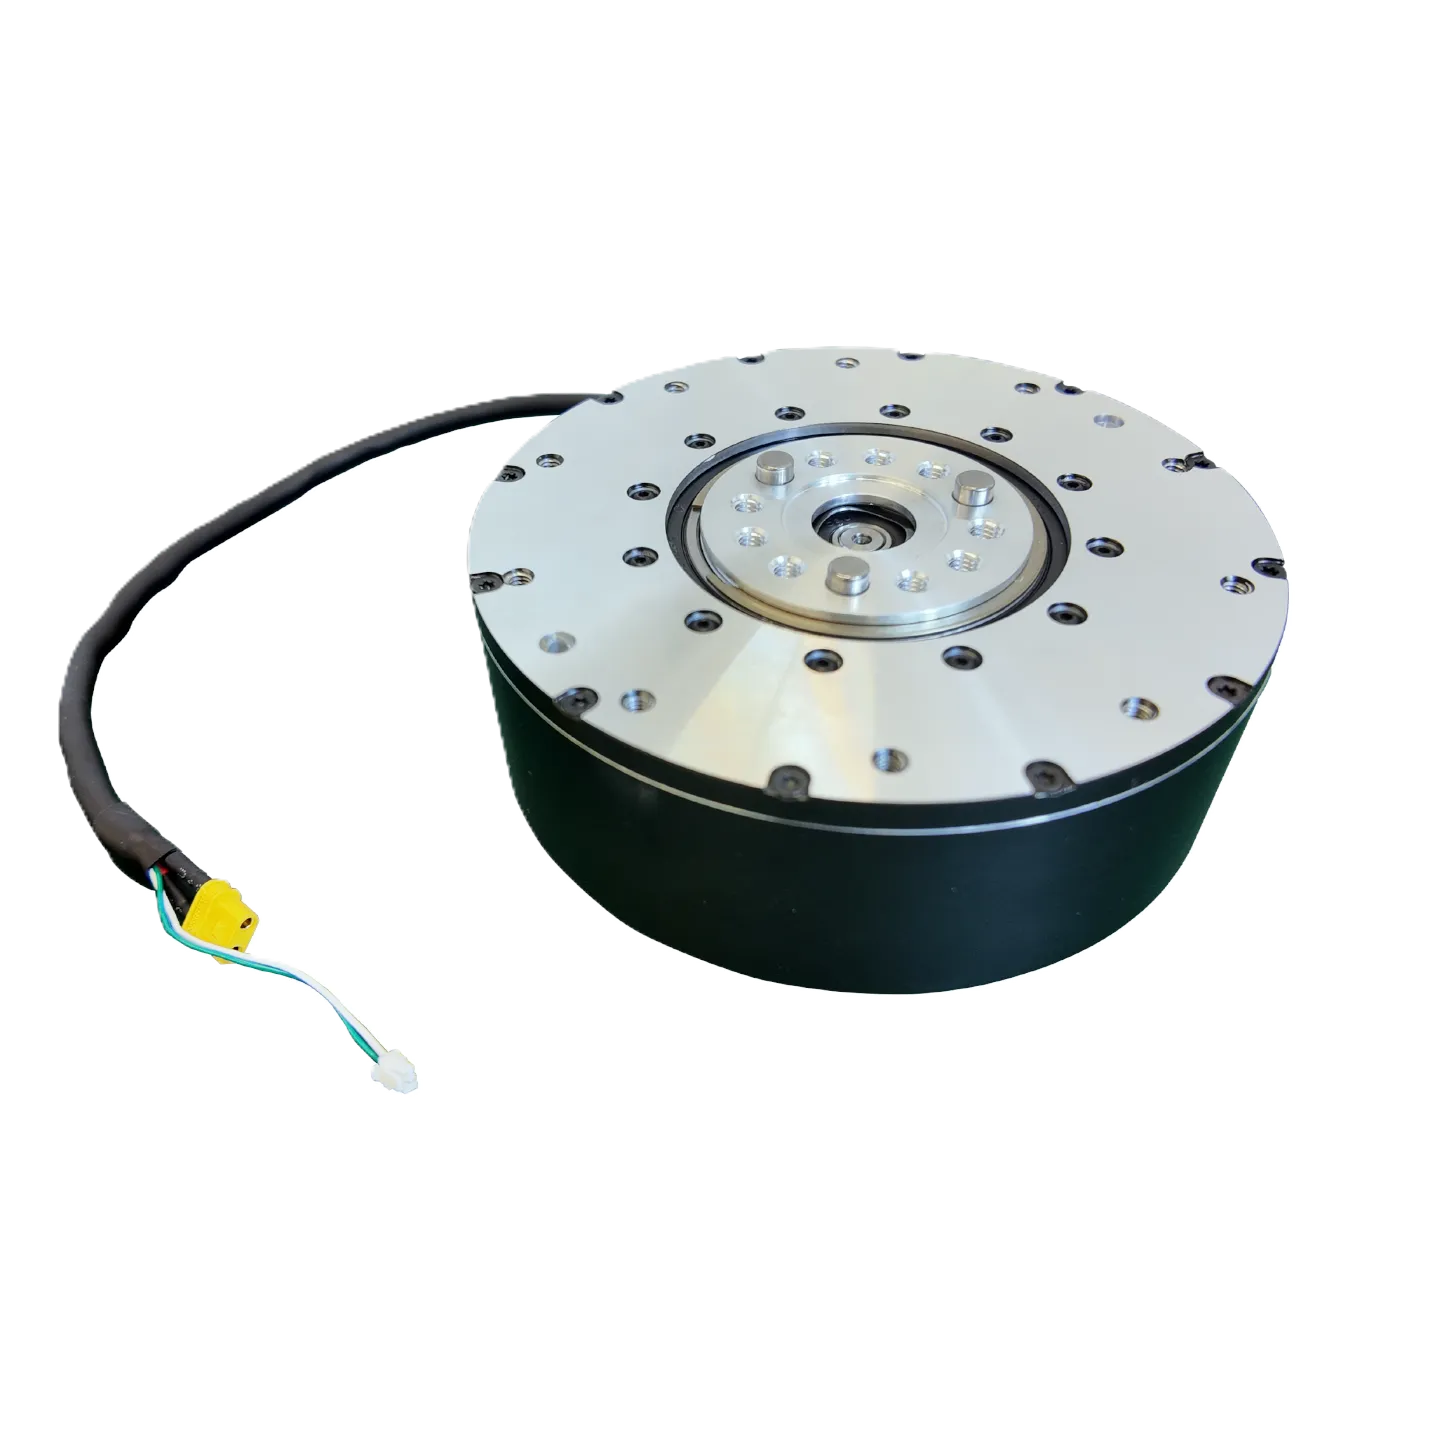
Select an image to inspect the original product photograph in a new tab.
Review the model parameters below. Download the catalog for complete technical documentation and configuration details.
Download Catalog (PDF) ↓| Parameter | Published value |
|---|---|
| Rated torque | 40 Nm |
| Peak torque | 120 Nm |
| Weight | 1420 g ± 20 g |
| Reduction Ratio | 9 : 1 |
| Drive Method | FOC |
| Encoder Type | Magnetic Encoder (2 pcs) |
| Rated Voltage | 48 V |
| Operation Voltage Range | 15 - 60 VDC |
| Rated Output Power | 420 W ± 10% |
| No-load Speed | 200 rpm ± 10% |
| Rated Load Speed | 100 rpm ± 10% |
| Rated Load Phase Current | 27 Apk ± 10% |
| Peak Phase Current | 90 Apk ± 10% |
| Communication interface | Confirm the interface and configuration with engineering before design-in. |
Communication boundary: Communication: model-specific; contact engineering to confirm the interface before design-in. ZHR-P60 is CAN only and does not support native EtherCAT.
Inspect the model-specific mounting interfaces before designing the mating parts.
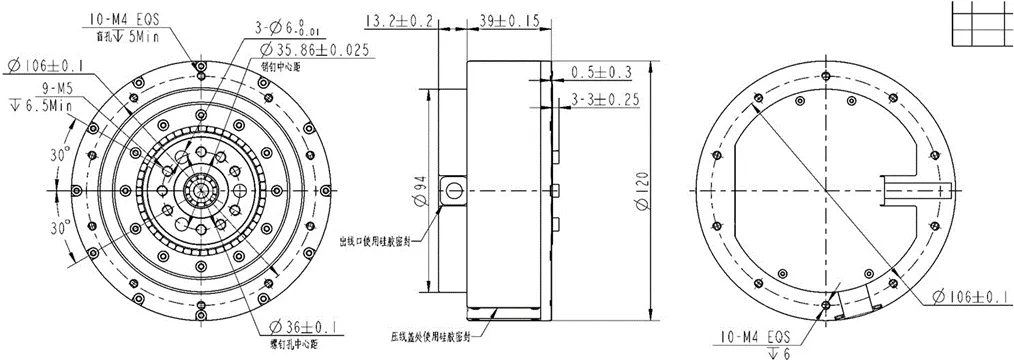
Use the series specification page for the current public drawings and data. Request model-specific documents, configuration confirmation and quotation with your application conditions.
Read the ZHR-P120 catalog page with electrical, mechanical and operating data.
Open ZHR-P120 catalog page ↗Check the current series documentation alongside the model drawing and comparison data.
View series spec sheets →Ask for the current ZHR-P120 STEP model, interface confirmation and quotation for your configuration.
Request engineering review for ZHR-P120 →Compare published ratings first, then validate speed, packaging and controls. Weight alone does not determine application suitability.
| Model | Rated torque | Peak torque | Weight | Model page |
|---|---|---|---|---|
| ZHR-P05 | 1.6 Nm | 5.5 Nm | 191 g | View model details |
| ZHR-P14 | 5 Nm | 14 Nm | 310 g ± 3 g | View model details |
| ZHR-P17 | 6 Nm | 17 Nm | 380 g ± 3 g | View model details |
| ZHR-P36 | 11 Nm | 36 Nm | 621 g | View model details |
| ZHR-P60 | 20 Nm | 60 Nm | 900 g ± 20 g | View model details |
| ZHR-P120 | 40 Nm | 120 Nm | 1420 g ± 20 g | Current model |
ZHR-P120 is listed at 40 Nm rated torque and 120 Nm peak torque. Peak torque is not a continuous operating rating. Confirm allowable peak duration, duty cycle and thermal conditions with engineering.
The catalog lists 48 V rated voltage. Check the operating voltage range and power supply requirements in the specification table before integration.
Confirm the interface and configuration with engineering before design-in.
Use the model-specific dimensional drawing on this page and the linked specification catalog for initial layout. Request the current ZHR-P120 STEP model and configuration confirmation through the engineering RFQ link before releasing your mechanical design.
ZHR-P120 has the highest published rated and peak torque in this six-model ZHR-P comparison. Its 40 Nm rated and 120 Nm peak figures make it the upper torque option in this range; confirm the full duty cycle and mounting before selection.
Share your required torque and speed, duty cycle, supply voltage, control interface and target quantity. Your inquiry carries the ZHR-P120 reference so the engineering team can review the intended configuration.